Product description
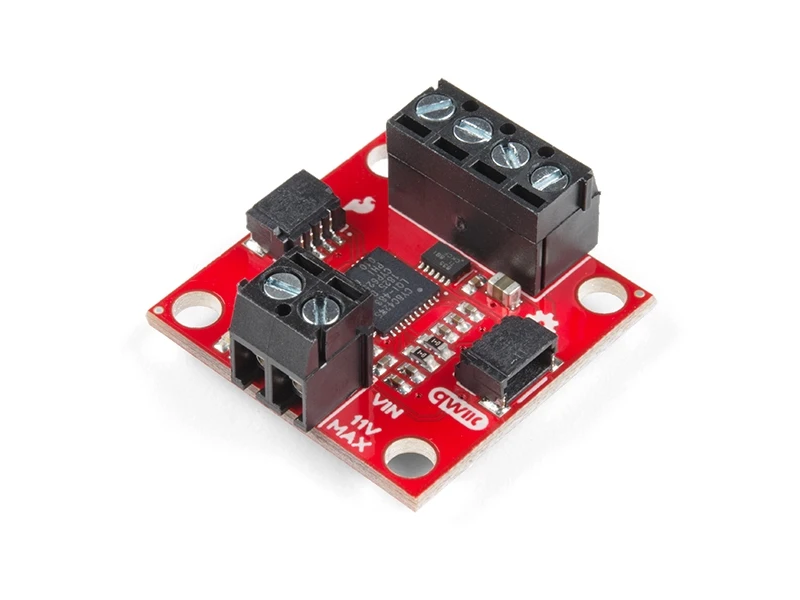
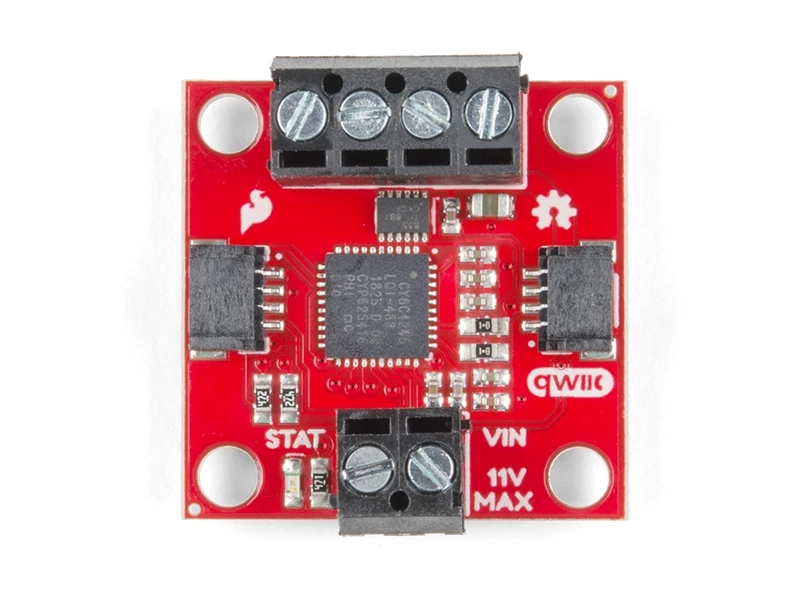
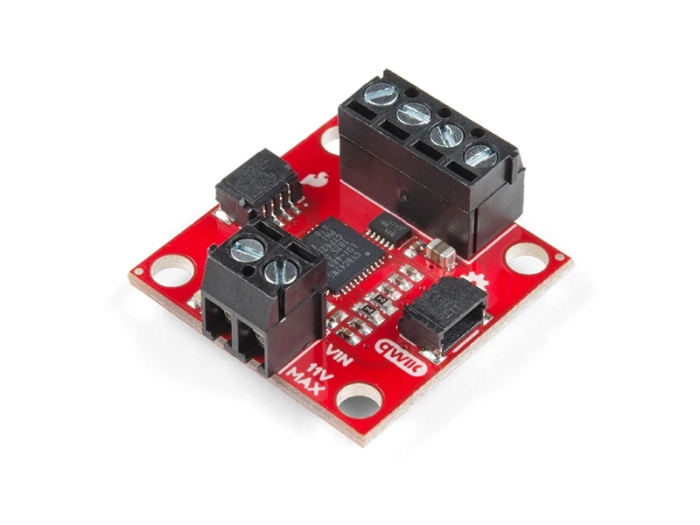
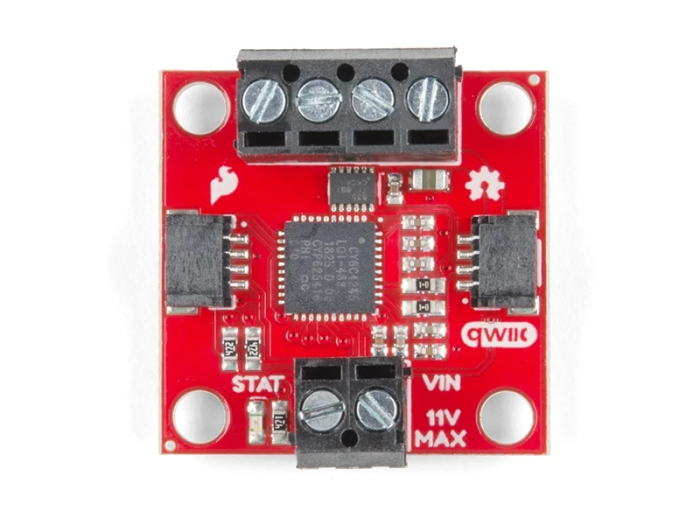
Two-channel motor controller with serial control (I2C or UART) and Qwiic connectors. Makes robot projects quick and easy. Solderless hookup with screw terminals and Qwiic connectors.
Allows simple daisy-chaining of multiple drivers (and/or other boards) on the same I2C bus.
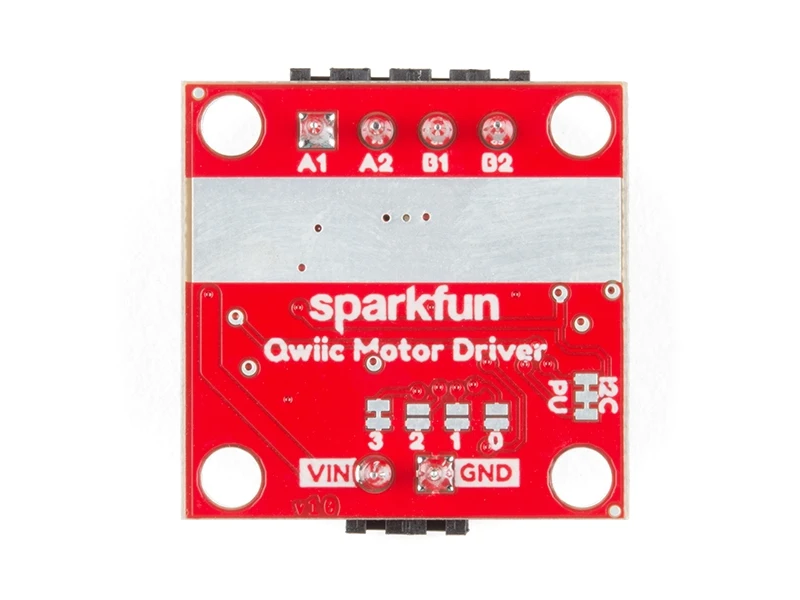
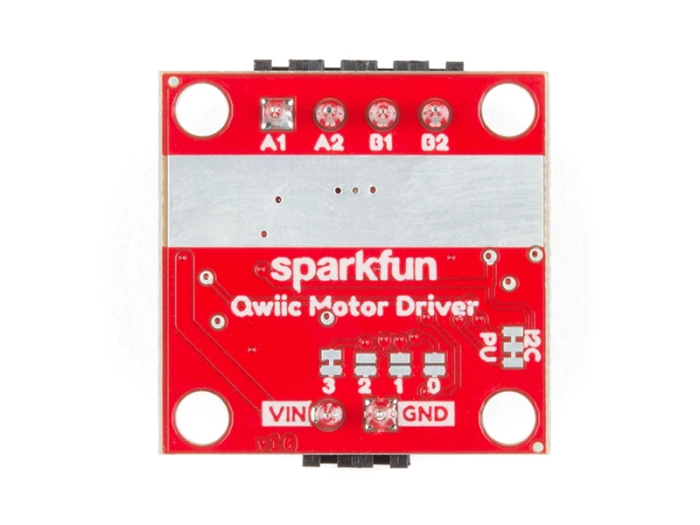
In addition to I2C, it can also be operated via UART. The choice of serial communication method and the I2C address or baud rate are configured using four solder jumpers.
There are 11 selectable I2C addresses, allowing for up to 22 channels of motor control on a single I2C bus. When using multiple I2C devices on the same bus, all but one of the I2C pull-up jumpers must be disconnected (opened).
Specifications:
- Max 1.2 A continuous current per channel (1.5 A for short periods)
- Operating voltage from 3 to 11 V
- 3.3V logic and supply voltage
- Controlled via simple commands – just select the motor, direction, and speed
- 127 levels of drive strength
- Motors can be reversed individually
- Choose between I2C and UART
- Exposed copper on the back allows for mounting on a heatsink
- Eleven I2C addresses to choose from
- UART baud rate can be changed via jumpers or a serial command
- Two Qwiic connectors
- Dimensions: 25.4 x 25.4 mm
Solder jumpers and functions:
| Bits 3210 | Mode | Address / Baud |
| 0000 | UART | 9600 |
| 0011 | I2C | 0x58 |
| 0100 | I2C | 0x59 |
| 0101 | I2C | 0x5A |
| 0110 | I2C | 0x5B |
| 0111 | I2C | 0x5C |
| 1000 (default) | I2C | 0x5D |
| 1001 | I2C | 0x5E |
| 1010 | I2C | 0x5F |
| 1011 | I2C | 0x60 |
| 1100 | I2C | 0x61 |
| 1101 | UART | 57600 |
| 1110 | UART | 115200 |
| 1111 | (reserved) | - |